The problem
Make something that exists in the physical world, not just in a notebook, and make it understand my own language without a cloud.
What I built
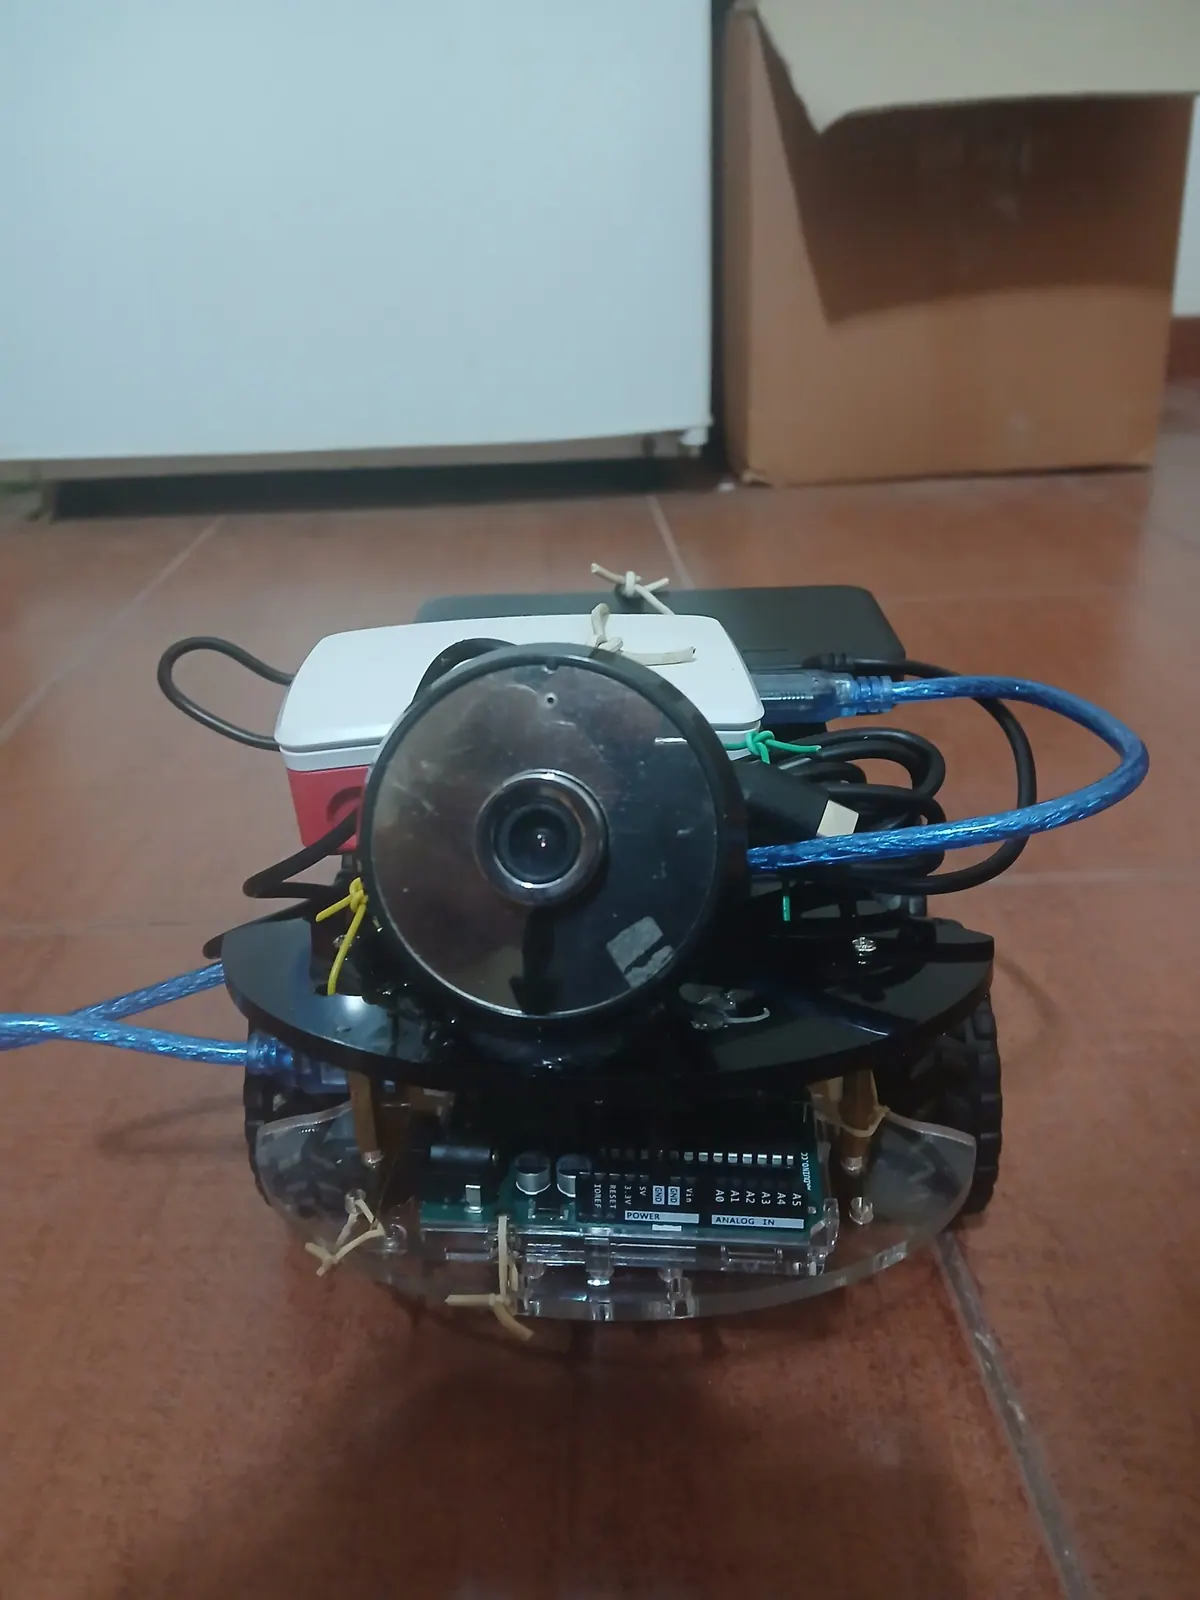
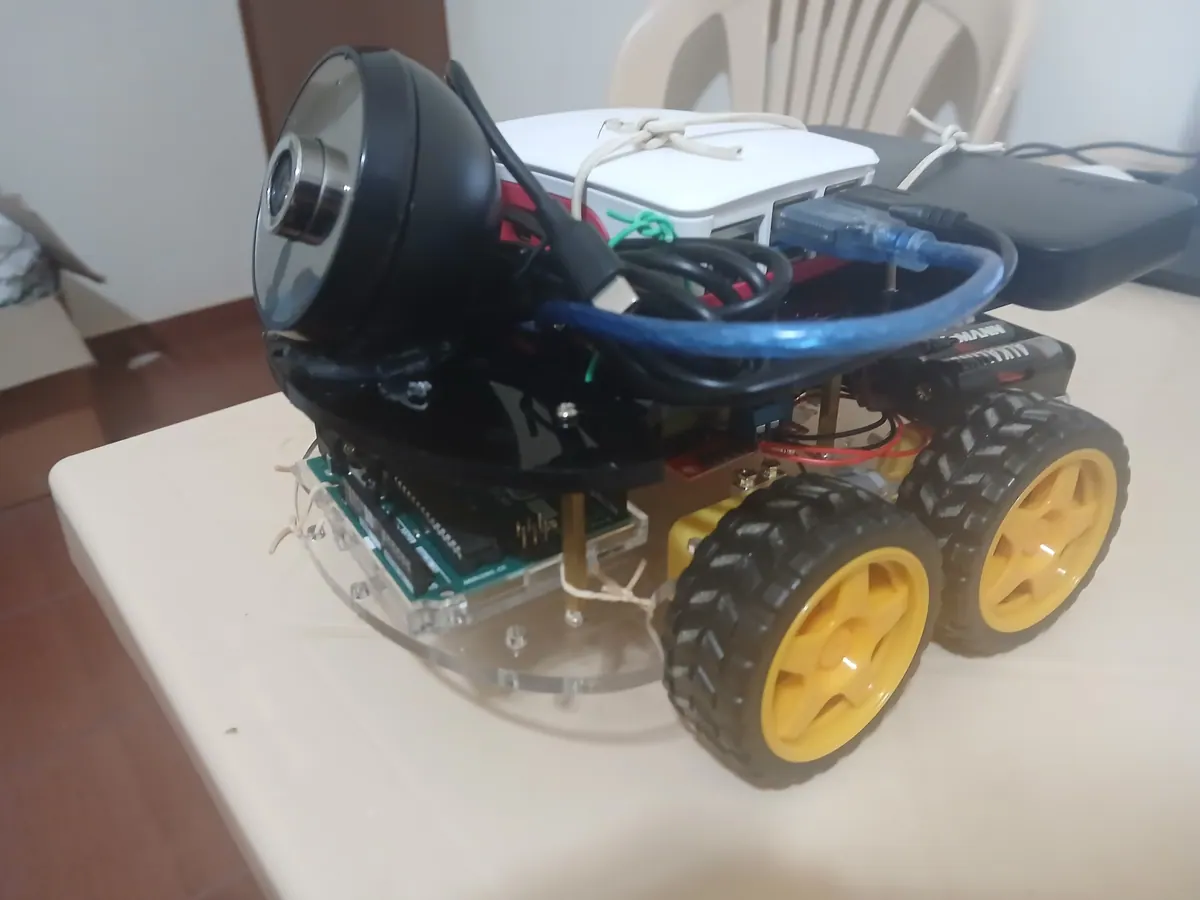
- Whisper speech-to-text with voice-activity detection and noise reduction; bilingual keyword matching; Phi-3 Mini via Ollama for free-form requests.
- OpenCV colour tracking steers toward the target and scans when it is lost.
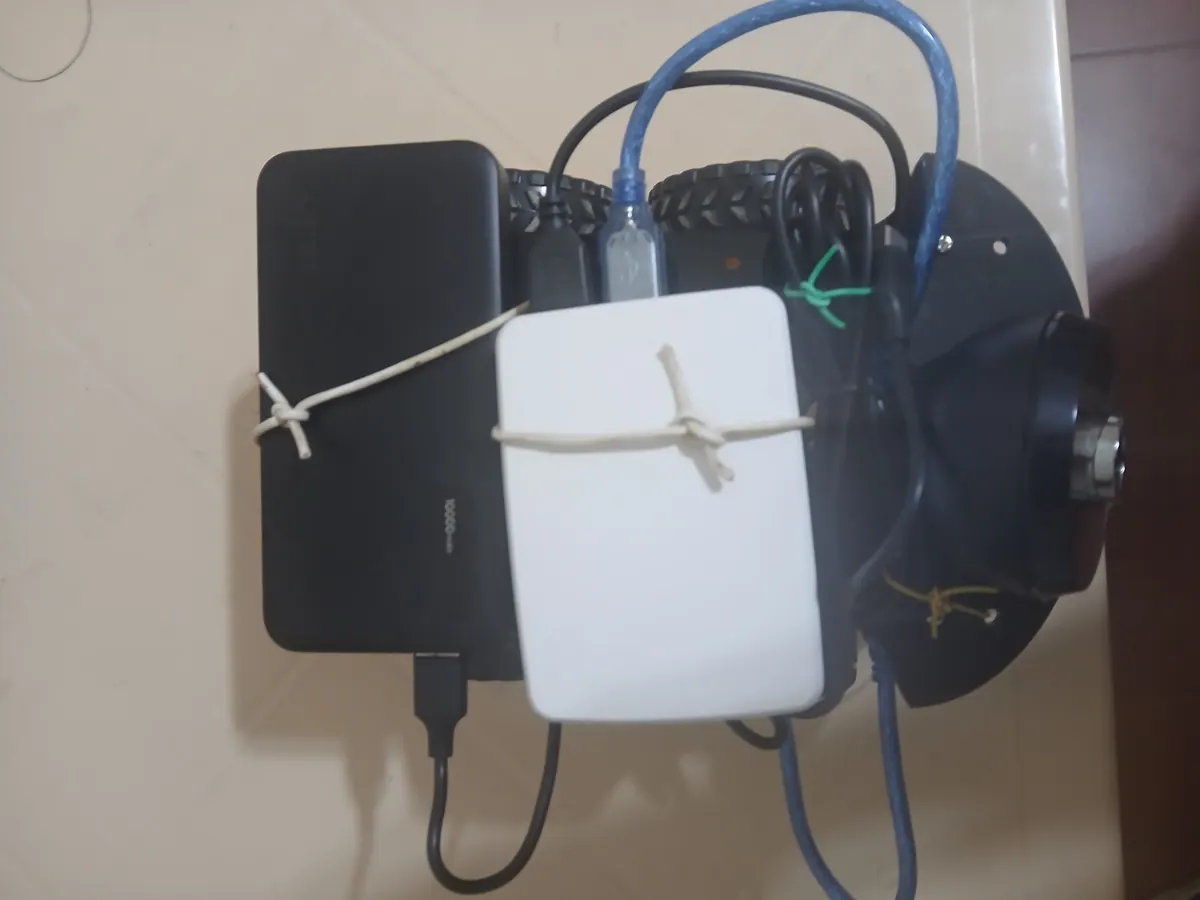
- Arduino Uno + L298N drive the chassis over serial; a local Whisper fallback keeps it working offline.
Result
Works end to end with no internet connection and no data leaving the device.
Drive Kimo
Kimo chases red objects with OpenCV. Drag the red ball around; the robot tracks it, scans when it loses sight, and bumps the counter when it catches it.
SCANNING…catches: 0
Drag the red ball
Gallery